publications
Publications organized by high-level research direction, with links to interactive articles and PDFs.
Hysteresis-Based Reinforcement Learning & Hybrid Supervision
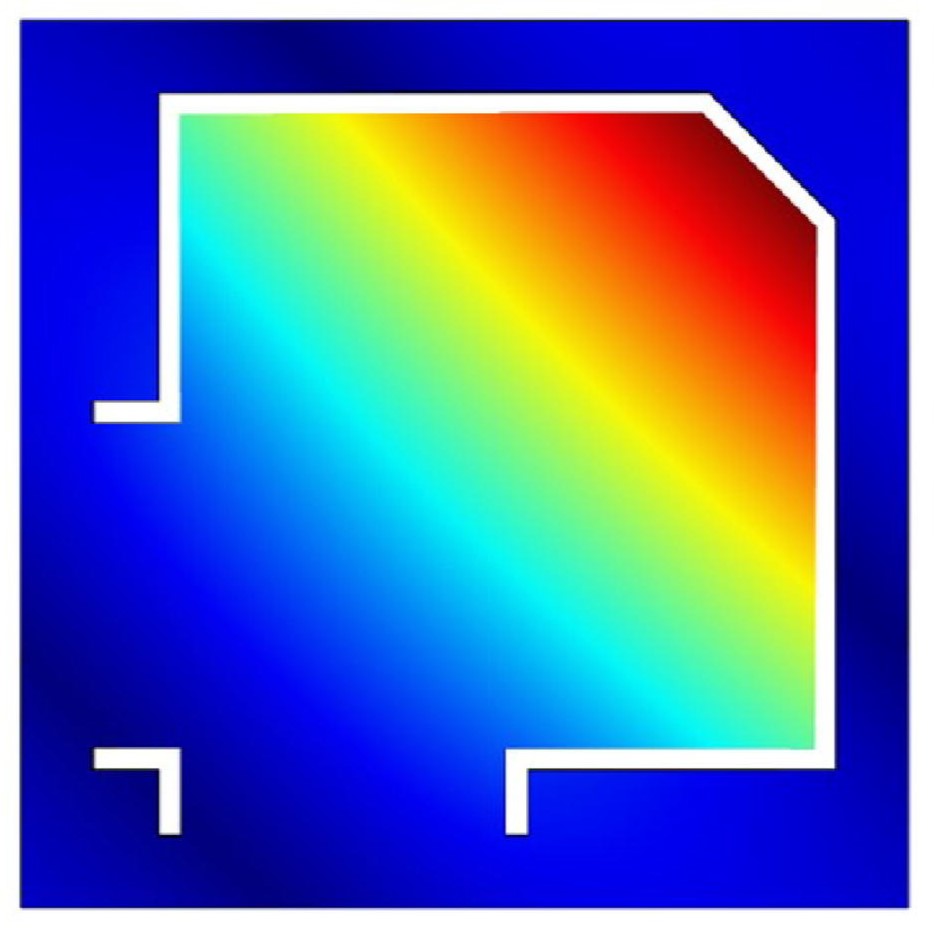
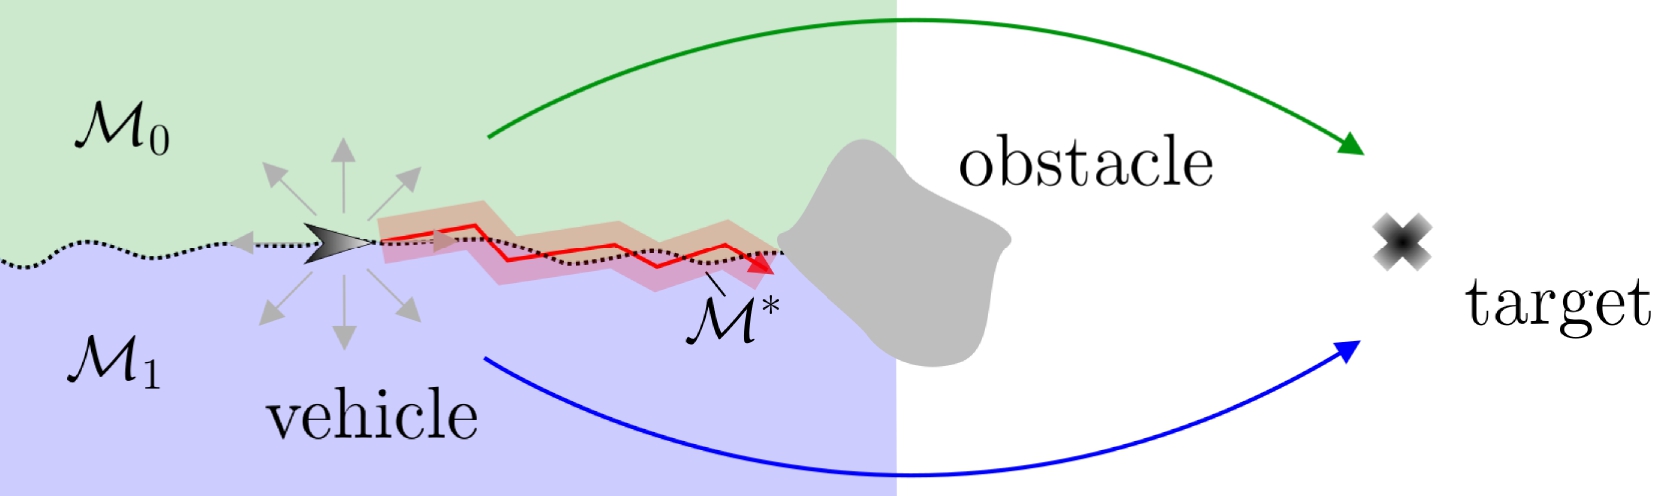
Eliminating topological decision-boundary chattering in 2D and 3D autonomous navigation ($\text{SE}(3)$ & $\text{SO}(3)$) against adversarial observation perturbations using hysteresis-based RL and predictive timer supervisors. [Read Hysteresis-Based RL Article →]



Foundations & Intrinsic Stability of Reinforcement Learning
Proving that the unmodified discounted reinforcement learning objective intrinsically guarantees closed-loop practical asymptotic stability for continuous control tasks—modeling discounting and neural network approximation errors as bounded disturbances. [Read Intrinsic Stability Article →]

Physical Robotics & Real-World Robustness Validation
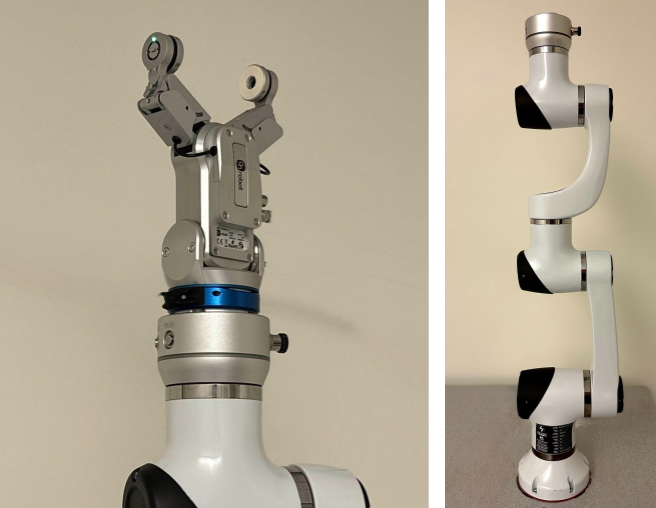
Demonstrating that theoretical and simulation-tested hysteresis robustness scales reliably to physical hardware—including onboard deployment of the simulation-derived L-MultiHyRL closed-loop hybrid system on a physical quadrotor (listed under Direction I above) and hysteresis-based contact and force regulation on a 6-DoF robotic manipulator. [See Quadrotor Flight Validation →]
Applied Physics & Acoustic Metamaterials
Optimization of thermo-viscous frequency stop-bands in micro-slit resonant acoustic metamaterials.